MABRADA DOO · MANUFACTURING SINCE 1986 · ČAČAK, SERBIA
+381 66 90 52 250office@mabrada.comInstagram · @mabrada.rs ↗
MABRADA
EN/SR
ROBOTICS AND INDUSTRIAL AUTOMATION · ČAČAK

We do not just sell a robot.
We build a process that works.

We identify where automation makes sense, select the right robotic platform and take responsibility for engineering, manufacturing, programming and commissioning the complete cell.
Explore applications↓
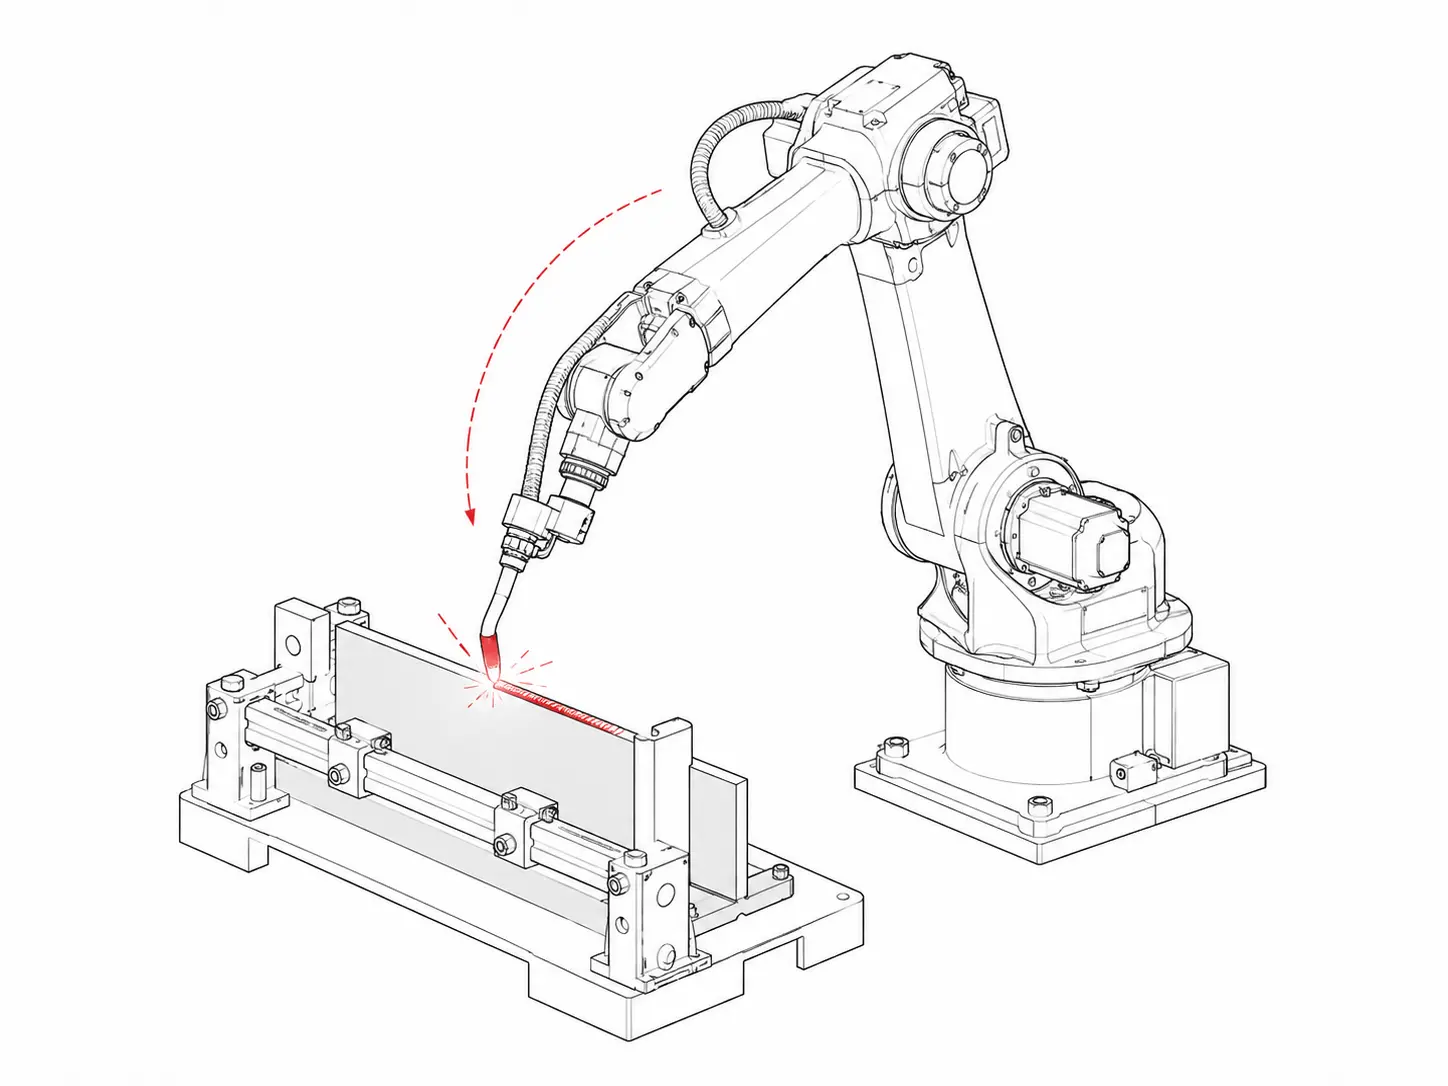
Technical diagram of a robotic welding cellMABRADA / CELL ENGINEERING
WHAT MABRADA DELIVERS

One accountable partner for the complete solution.

01

Analysis and concept

We study the current work, measure cycle time and define where automation creates real value.

02

Engineering and build

We select the robot and engineer the tooling, base, guarding and custom cell components.

03

Integration and support

We connect machines, sensors and controls, program the cycle and commission the system.

AUTOMATION APPLICATIONS

Choose the production problem you want to remove.

Every solution is engineered around the actual workpiece, cycle time and space. The diagrams show the principle; the final cell is defined only after reviewing your process.

Robotic welding01

Robotic welding

Problem we solve
Weld quality depends on the operator, the work is demanding and the same assembly repeats in series.
What we deliver
Robot, torch, source, positioner or fixture, guarding, path program and cycle optimisation.
Best fit when
You have repeatable welded assemblies, consistent joint preparation and need more capacity.
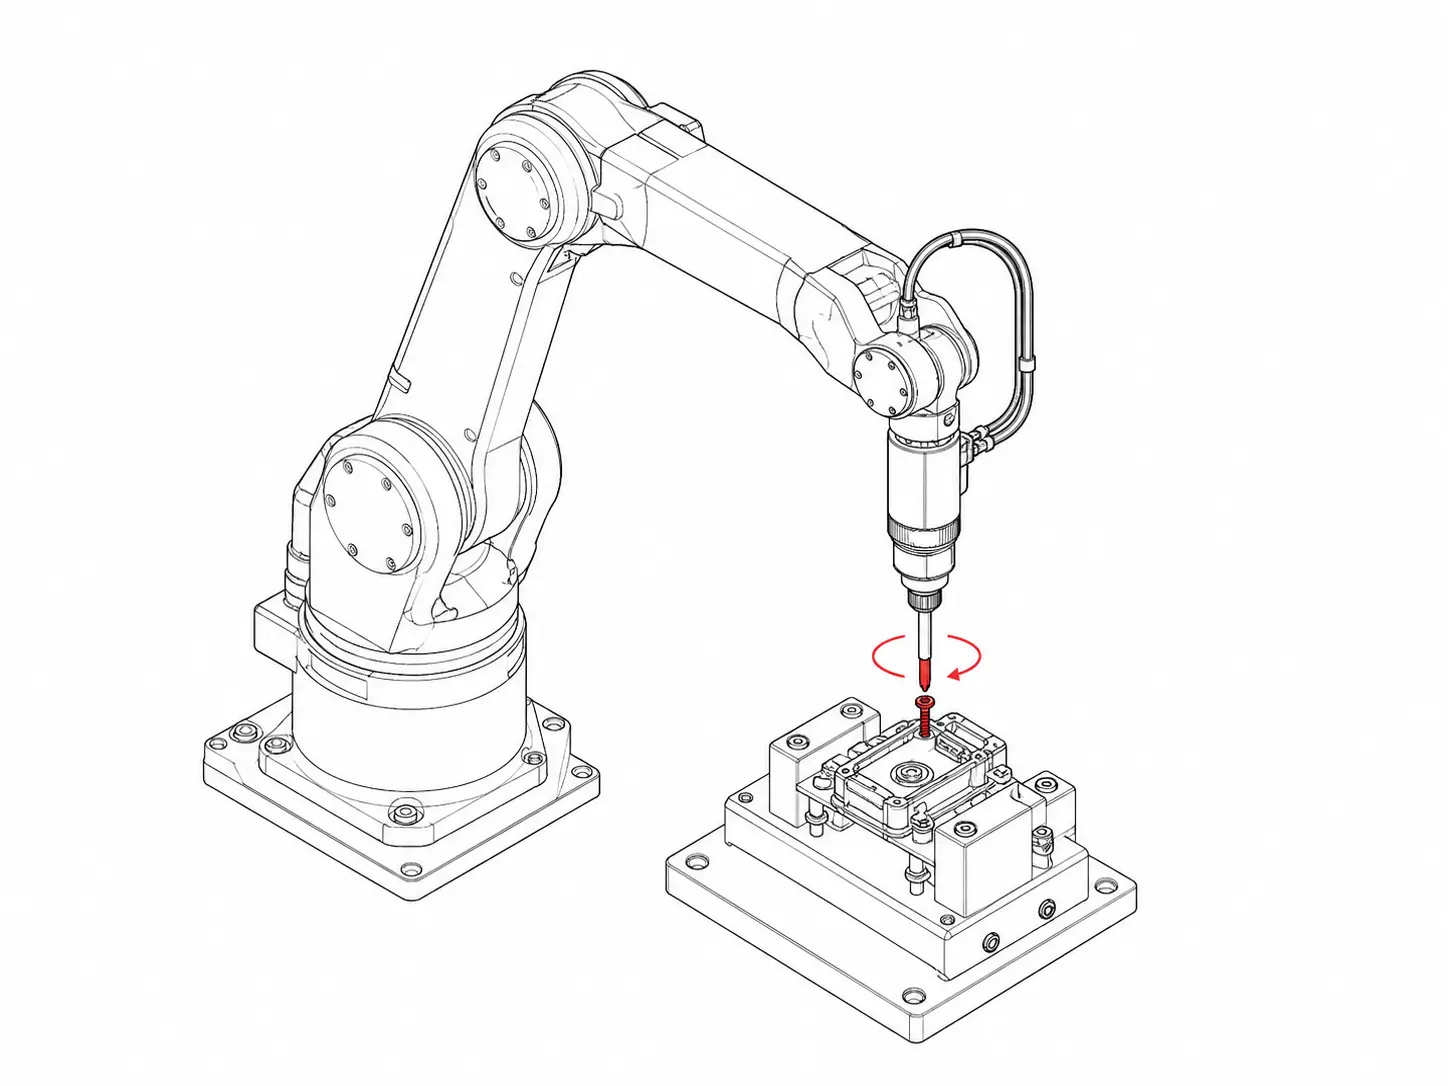
Fastening and assembly02

Fastening and assembly

Problem we solve
Manual fastening creates torque variation, slows assembly and makes quality tracking difficult.
What we deliver
Robot, torque-controlled tool, screw feeding, fixture, sensors and cycle-result recording.
Best fit when
You have serial assembly with several fastening points or traceability requirements.
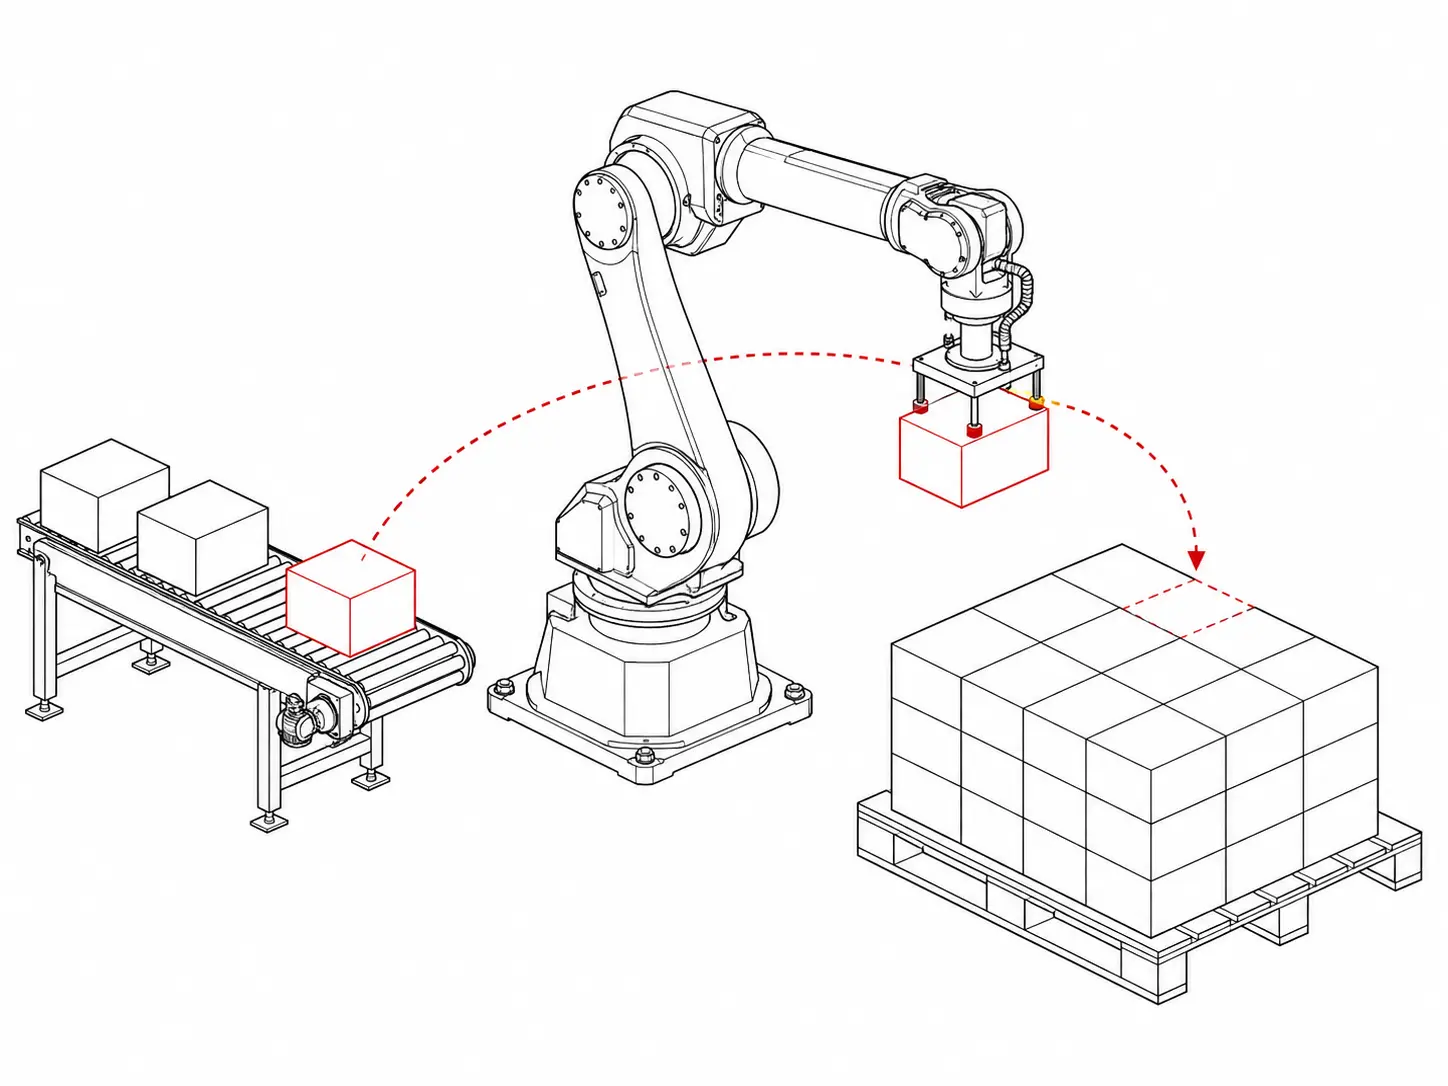
Palletising and depalletising03

Palletising and depalletising

Problem we solve
Workers lift loads, the task is monotonous and the end of line becomes a bottleneck.
What we deliver
Robot, gripper, product infeed, base, guarding and programs for multiple pallet patterns.
Best fit when
Products arrive at a stable rate, formats repeat and multiple-shift operation is required.
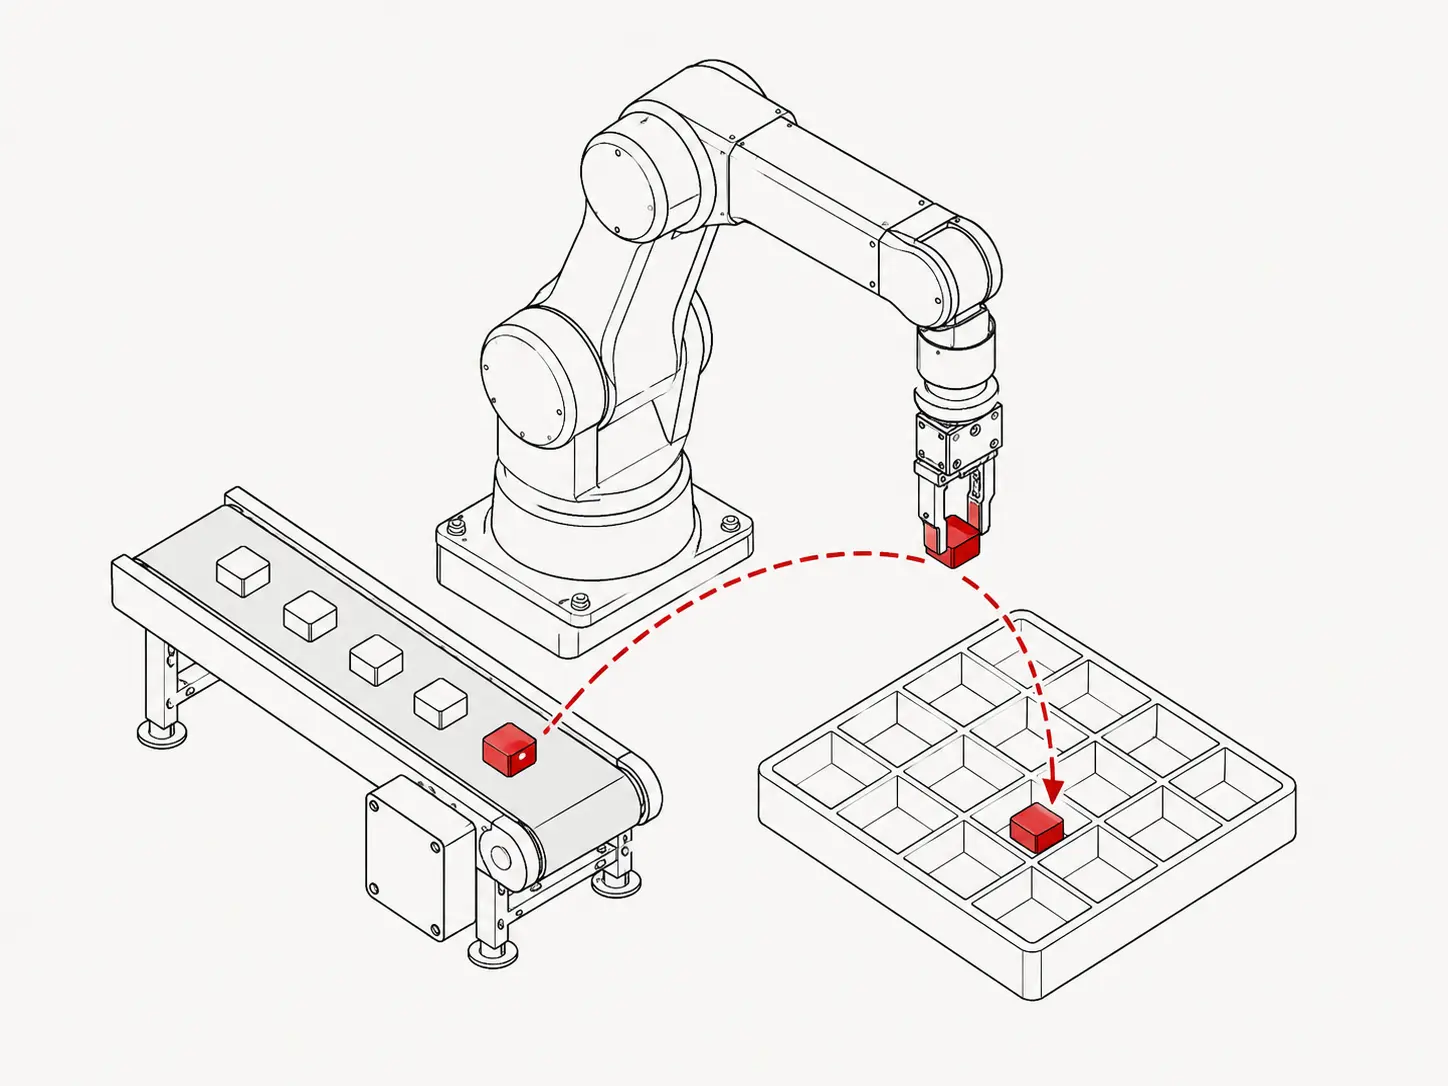
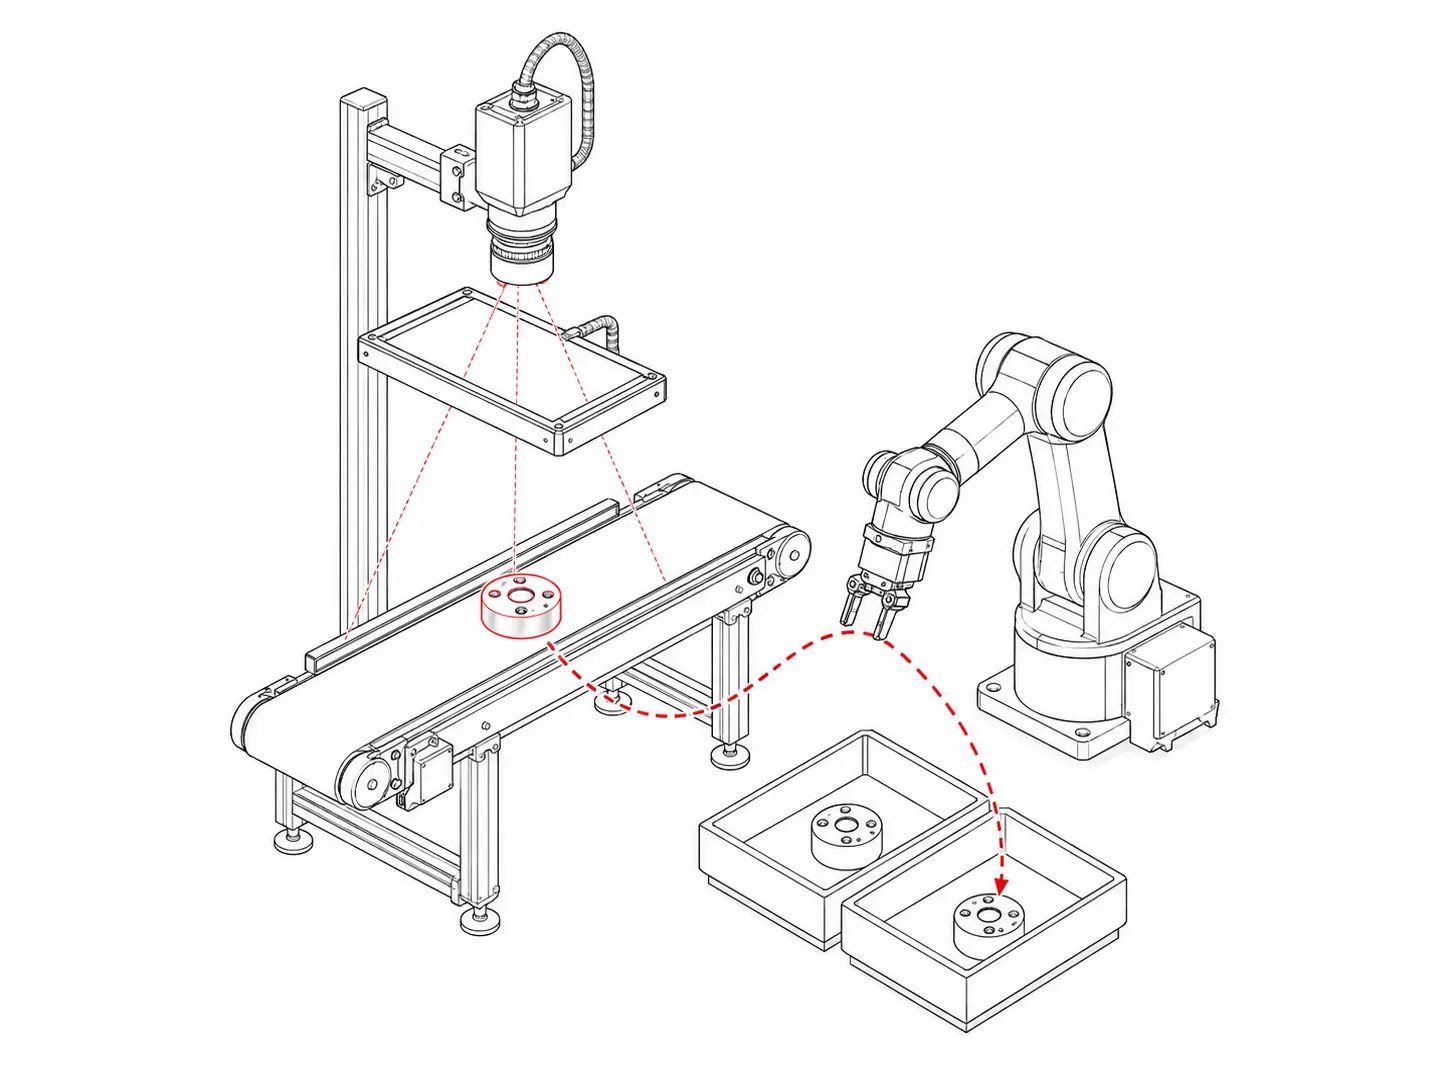
Pick & Place and sorting04

Pick & Place and sorting

Problem we solve
Fast manual picking and sorting limits capacity and increases handling errors.
What we deliver
Robot or SCARA platform, gripper, conveyor, sensors or camera and sorting logic.
Best fit when
Parts repeat, can be detected reliably and require fast accurate transfer.
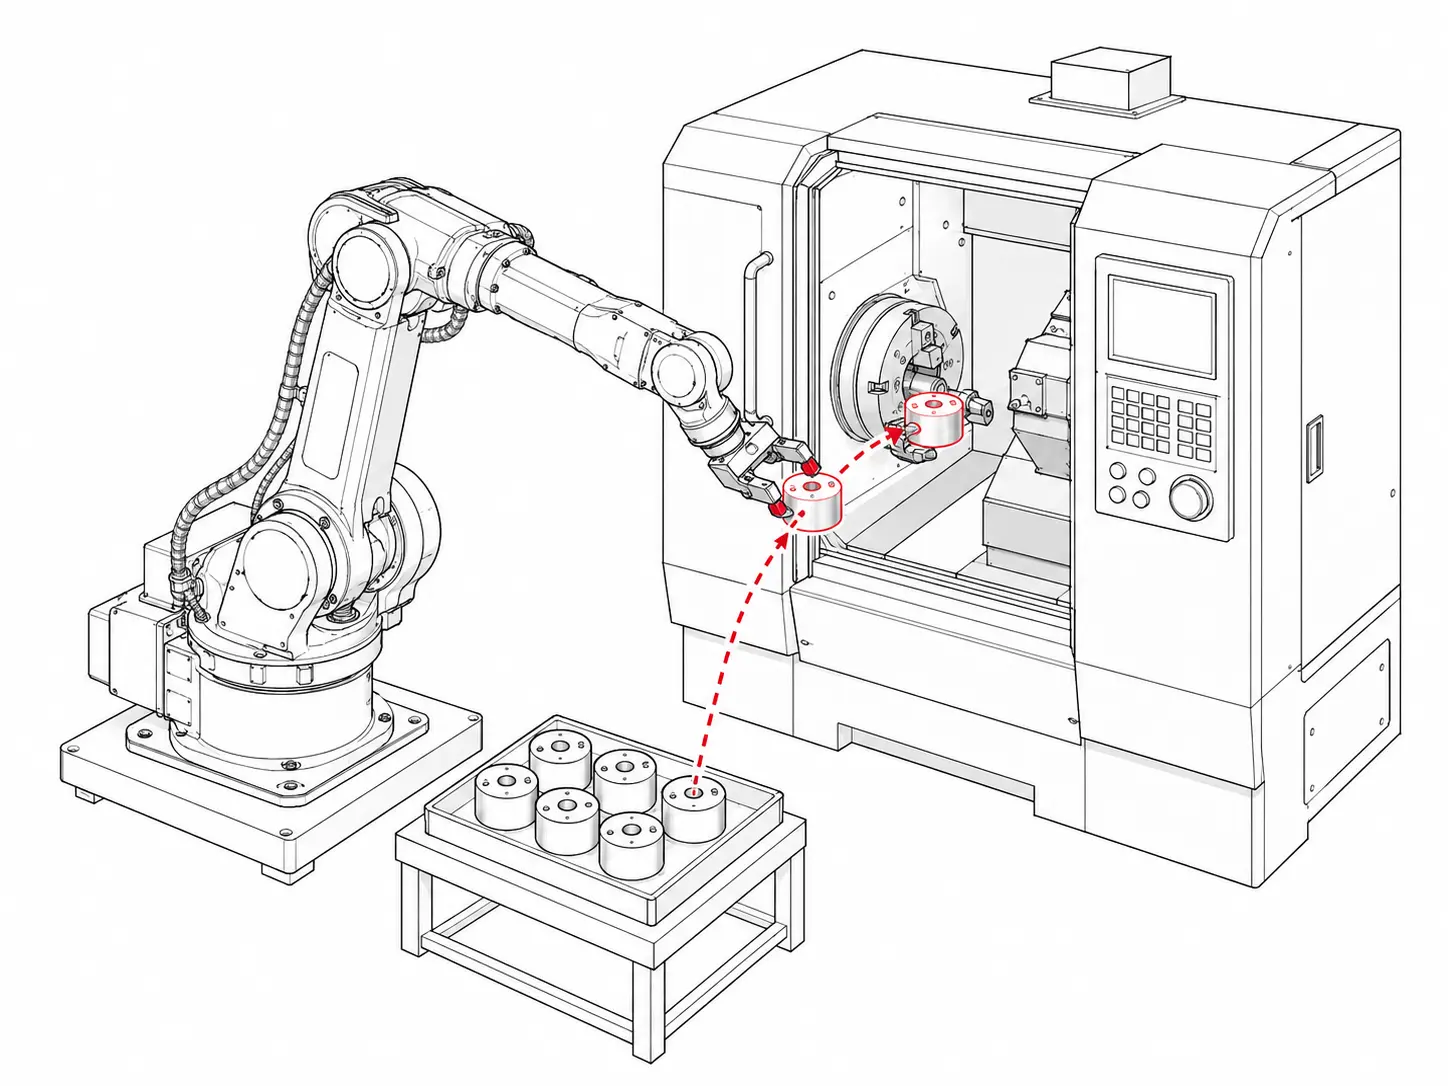
CNC machine tending05

CNC machine tending

Problem we solve
The operator waits for the machine cycle, loads parts manually and cannot supervise several machines.
What we deliver
Robot, raw-part magazine, gripper, automatic door or interface, blow-off and part inspection.
Best fit when
You have a stable machining process, repeat parts and enough cycle time for automated loading.
Vision and inspection06

Vision and inspection

Problem we solve
Orientation or quality defects are hard to detect manually and depend on operator attention.
What we deliver
Industrial camera, lighting, algorithm, station mechanics and integration with robot or PLC.
Best fit when
The inspected feature can be clearly seen, measured or compared by a camera.
COMPLETE ROBOTIC CELL

The robot is only the start. We connect everything that makes it productive.

01Robot and controller→
02Gripper or process tool→
03Base, fixture and guarding→
04Sensors, vision, PLC and HMI→
05Software, testing and training
FROM IDEA TO A STABLE CYCLE

How we develop the solution.

01

Process review

Video, photographs, the workpiece and a discussion give us the starting data.

02

Technical assessment

We verify cycle time, payload, reach, space, safety and return on investment.

03

Engineering

We develop the layout, mechanics, tooling, controls and cycle logic.

04

Delivery

We manufacture, connect, program, test and commission the cell.

Send a short process video.

Include the operation, workpiece dimensions and mass, current cycle time, shifts and available space. If the data is incomplete, a short problem description is enough for the first discussion.

Production and contact

Trnava, Čačak, Serbia

43°51'54.8"N 20°24'33.0"E

Open exact location↗